
K6D80ri 6-axis force/torque sensor 1 kN/100 Nm, EtherCAT P
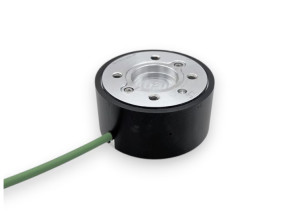
- Simultaneous measurement of 6 components: Fx, Fy, Fz, Mx, My, Mz
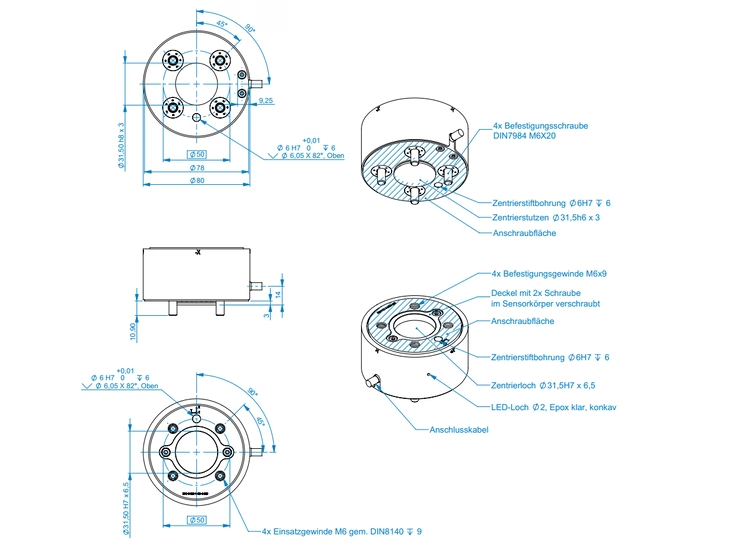
- ISO 9409-1-50-4-M6 robot flange
- Integrated GSV-61i signal conditioner, EtherCAT P interface
- Single 4-conductor cable for power and data
- Nominal forces: Fx, Fy 1 kN; Fz 2.5 kN
- Nominal moments: Mx, My, Mz 100 Nm
- Crosstalk: 1 % FS
- IP65, aluminum alloy body
Overview
The K6D80ri 1kN/100Nm/EC is a 6-axis force/torque sensor designed for robotics, medical technology and industrial automation. It simultaneously measures forces and moments in the three spatial directions (Fx, Fy, Fz, Mx, My, Mz). Its moment measuring range is wide for its compact dimensions: Ø 80 mm × 60 mm.
The sensor is based on a hexapod measuring structure: six sensing elements capture the applied forces. A 6×6 calibration matrix, determined individually, assigns the superimposed signals to each axis. The crosstalk is 1 % of full scale.
Key specifications
| Quantity | Value |
|---|---|
| Nominal force Fx, Fy | 1 kN |
| Nominal force Fz | 2.5 kN |
| Nominal moment Mx, My, Mz | 100 Nm |
| Relative linearity error | 0.2 % FS |
| Crosstalk | 1 % FS |
| Natural frequency fx | 2.4 kHz |
| Operating temperature range | −10 °C to +65 °C |
| Protection | IP65 |
Mechanical integration
The sensor features an ISO 9409-1-50-4-M6 robot flange. Forces are introduced via an internal thread and fastening is achieved through an annular surface. The body measures Ø 80 mm with a height of 60 mm; it is made of aluminum alloy.
Data acquisition
The GSV-61i signal conditioner, with an EtherCAT P interface, is integrated into the sensor. A single 4-conductor cable provides power supply and digital data transmission. It connects via a connector with strain relief beneath the mounting plate and can be replaced if necessary.
Calibration
The K6D80ri cannot be used without its calibration matrix: it is a mandatory accessory, ordered together with the sensor. Determined individually and documented, it converts the six measurement signals into forces Fx, Fy, Fz and moments Mx, My, Mz, and compensates for crosstalk between axes. The expanded measurement uncertainty (k = 2) is given axis by axis.
6-axis sensors up to 20 kN, including the K6D80ri, are calibrated with the SL calibration matrix. All its variants include:
- calibration for one nominal force, according to a standard or customer-defined load vector;
- 12 orientations along the coordinate axes;
- 36 calibration factors, which scale the sensor output signals to Fx, Fy, Fz, Mx, My, Mz;
- a calibration mark applied to the sensor;
- a factory calibration certificate traceable to DAkkS standards.
The variants differ in the number of load steps measured. Each load step is traversed in 3 series, up and down, in tension and compression, in positive and negative moment.
| Variant | Calibration | Load steps | Measurements | Second-degree correction (Matrix-Plus) | Matrix B |
|---|---|---|---|---|---|
| SL/2 | 2 points | 0 %, 100 %, 0 % | 12 × 3 × 3 | no | no |
| SL/4 | 4 points | e.g. 0 %, 10 %, 50 %, 100 %, 0 % | 12 × 5 × 3 | yes | yes |
| SL/6 | 6 points | e.g. 0 %, 20 %, 40 %, 60 %, 80 %, 100 %, 60 %, 20 %, 0 % | 12 × 9 × 3 | yes | yes |
| SL/10 | 10 points | 0 %, 10 %, 20 % … 100 %, 60 %, 20 %, 0 % | 12 × 14 × 3 | yes | yes |
The SL/2 sticks to a linear correction. The SL/4, SL/6 and SL/10 add Matrix-Plus, a second-degree correction matrix, and the "Matrix B", which reduces the residual error to the order of 0.2 to 0.5 %. The higher the number of load steps, the more finely the response curve of each axis is described.
Applications
- Collision detection and robot motion monitoring
- Force-guided robot teach-in and programming
- Force measurement in medical technology, prosthetics and orthotics
- Gait analysis and biomechanical studies
- Comfort and ergonomics measurements
- Type
- 6 axis sensor, 6 axes robotics
- Measuring Range
- 2.5 kN
- Moment capacity
- 100 Nm
- Number of Axis
- 6 Axis
- Nonlinearity (% FS)
- ± 0.2 %
- Hysteresis
- 0.2 % FS
- Nonrepeatability
- 0.2 % FS
- Aluminum alloy
- Operating temperature range
- -10 to 65 °C
- Zero Balance
- 0.2 %PE/°C
- Sensibilité du gain
- 0.05 %/°C
- Output Signal
- 0.5 , 0.8 mV/V
- Résistance du pont
- 350 Ω
- Tension d'alimentation
- 2.5 - 5 VDC
- Cable
- 4-conductor cable
- Measurement direction
- Traction & Compress.
- Déflection
- 0.05 mm
- Surcharge
- 300 %PE
- Housing
- Aluminium
- Protection Class
- IP65
- Application
- Robotics
- Diameter: 80 mm
- Height: 60 mm
- Robot flange: ISO 9409-1-50-4-M6
- Force introduction: internal thread
- Fastening: annular surface
- IP68 version: for nominal forces of 200 N and above
- Extended temperature range: −40 °C to +85 °C
- Vacuum version: for vacuum applications down to a residual pressure of 10⁻⁵ mbar
- Pressure-resistant version: up to 8 bar
- SL calibration matrix (required), at choice:
- SL/2: 2-point calibration, linear correction
- SL/4: 4-point calibration, with Matrix-Plus (second degree) and Matrix B
- SL/6: 6-point calibration, with Matrix-Plus (second degree) and Matrix B
- SL/10: 10-point calibration, with Matrix-Plus (second degree) and Matrix B
 +33 1 46 91 93 32
 Contact form
 Subscribe to the newsletter